IETF 127 hackathon · LAKE WG
DotBots
in the LAKE
The LAKE handshake (EDHOC, RFC 9528) on a swarm of robots, over the air.
Geovane Fedrecheskigeovane.fedrecheski@inria.fr
San Francisco · November 2026
The LAKE handshake (EDHOC, RFC 9528) on a swarm of robots, over the air.
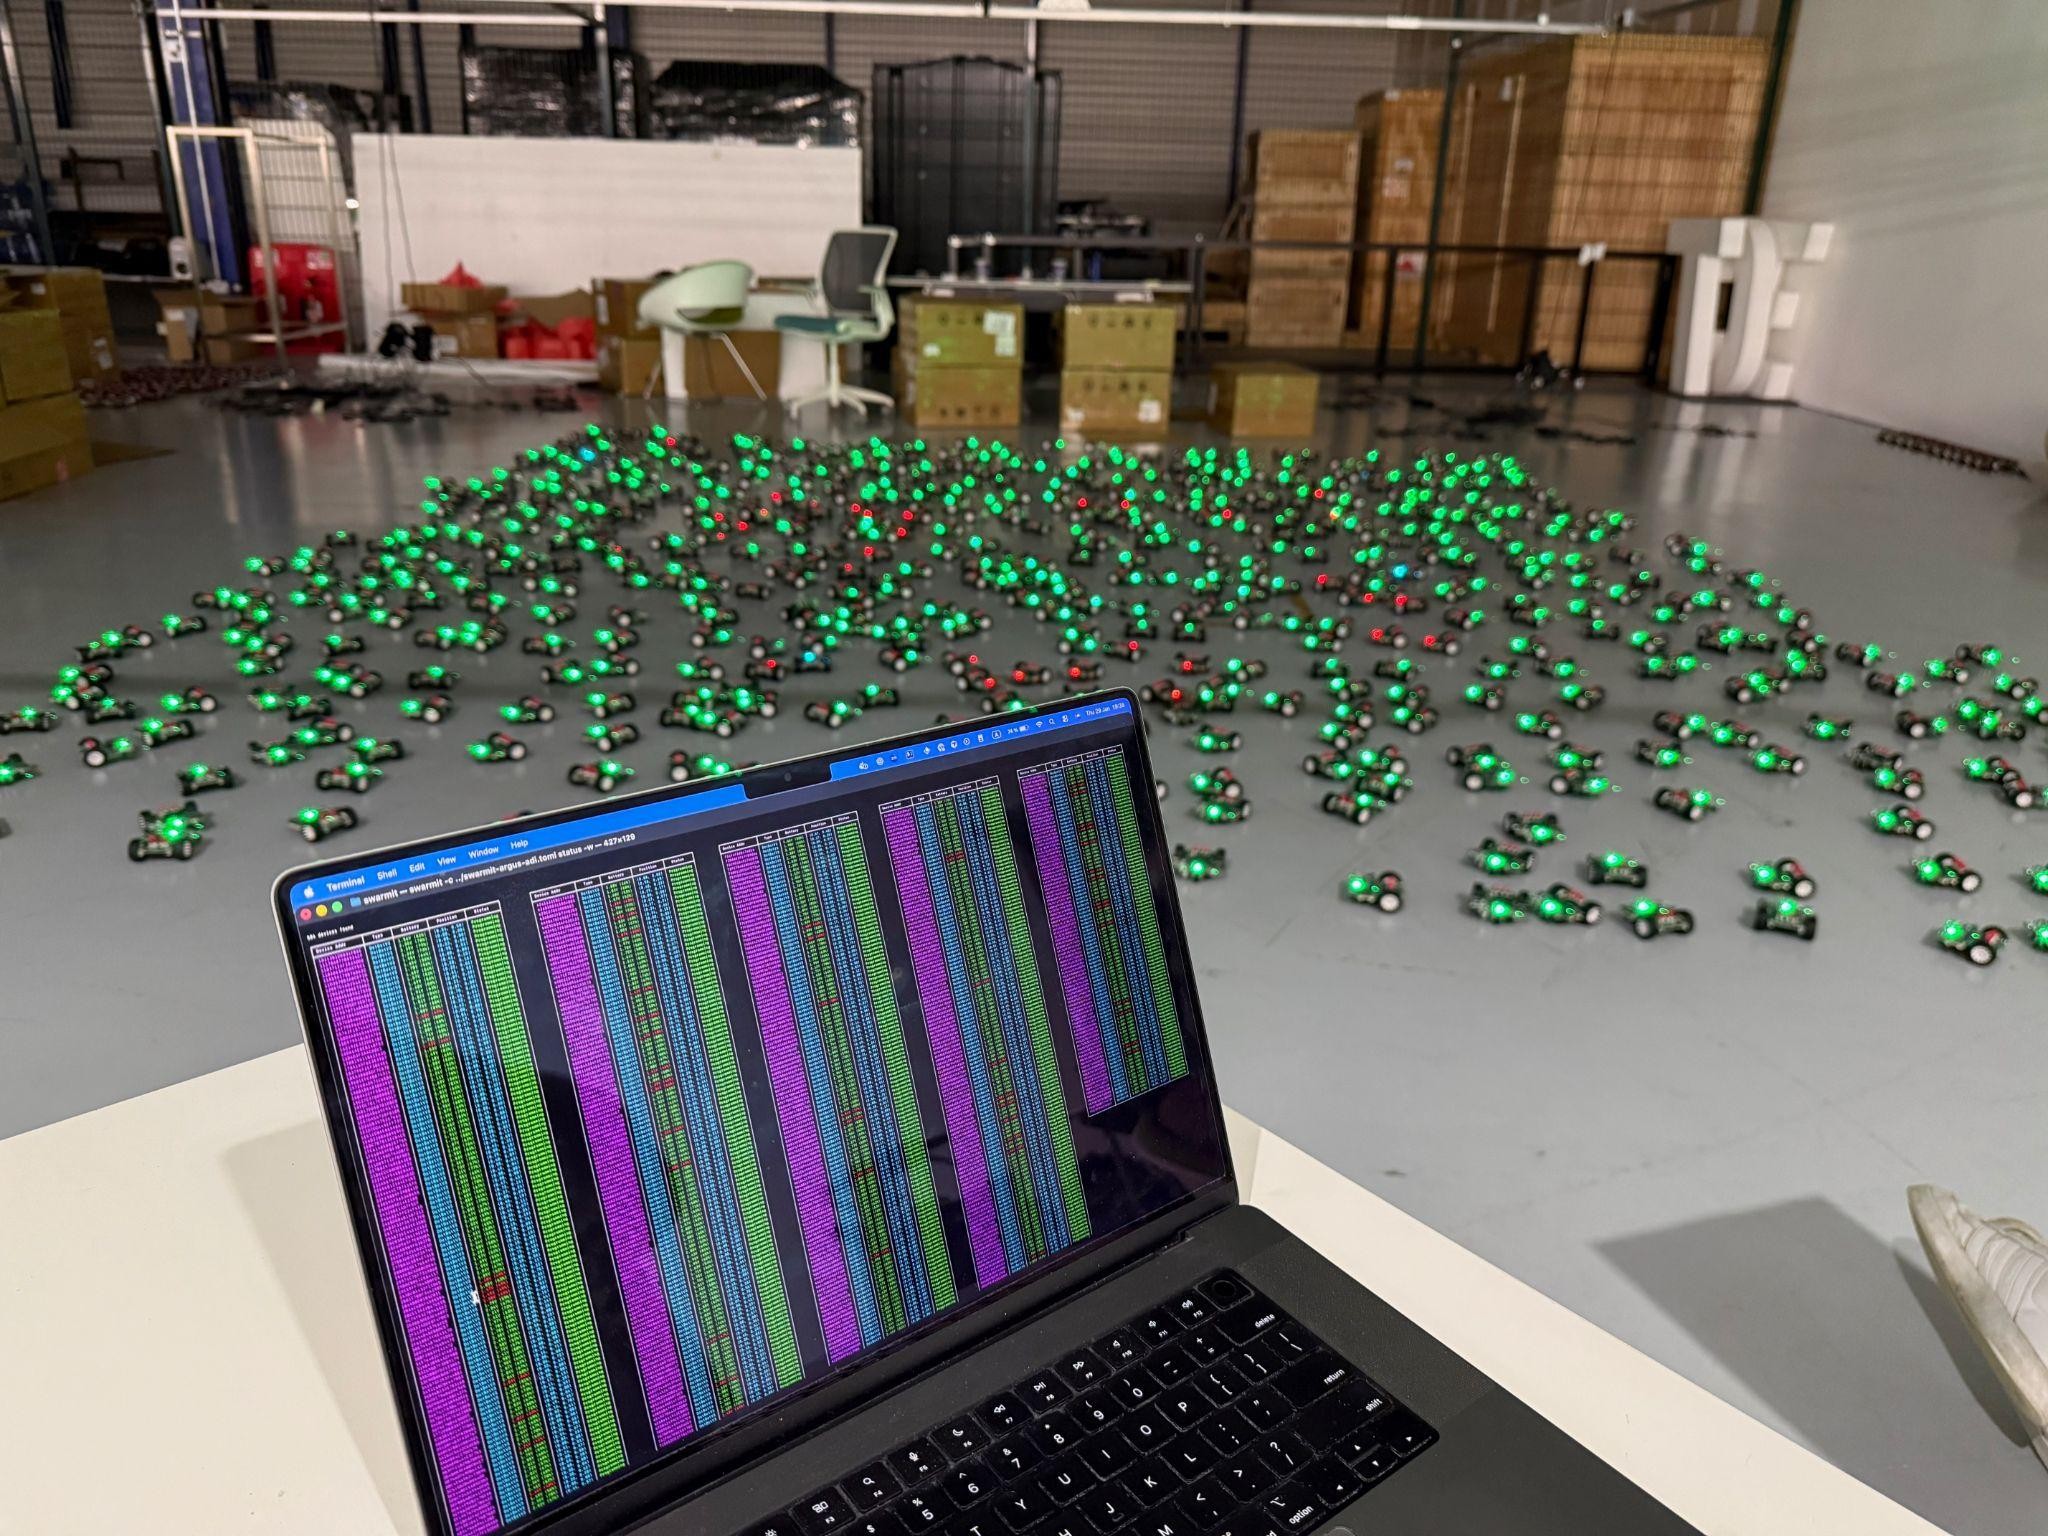
We want IETF protocols to run on all of them.
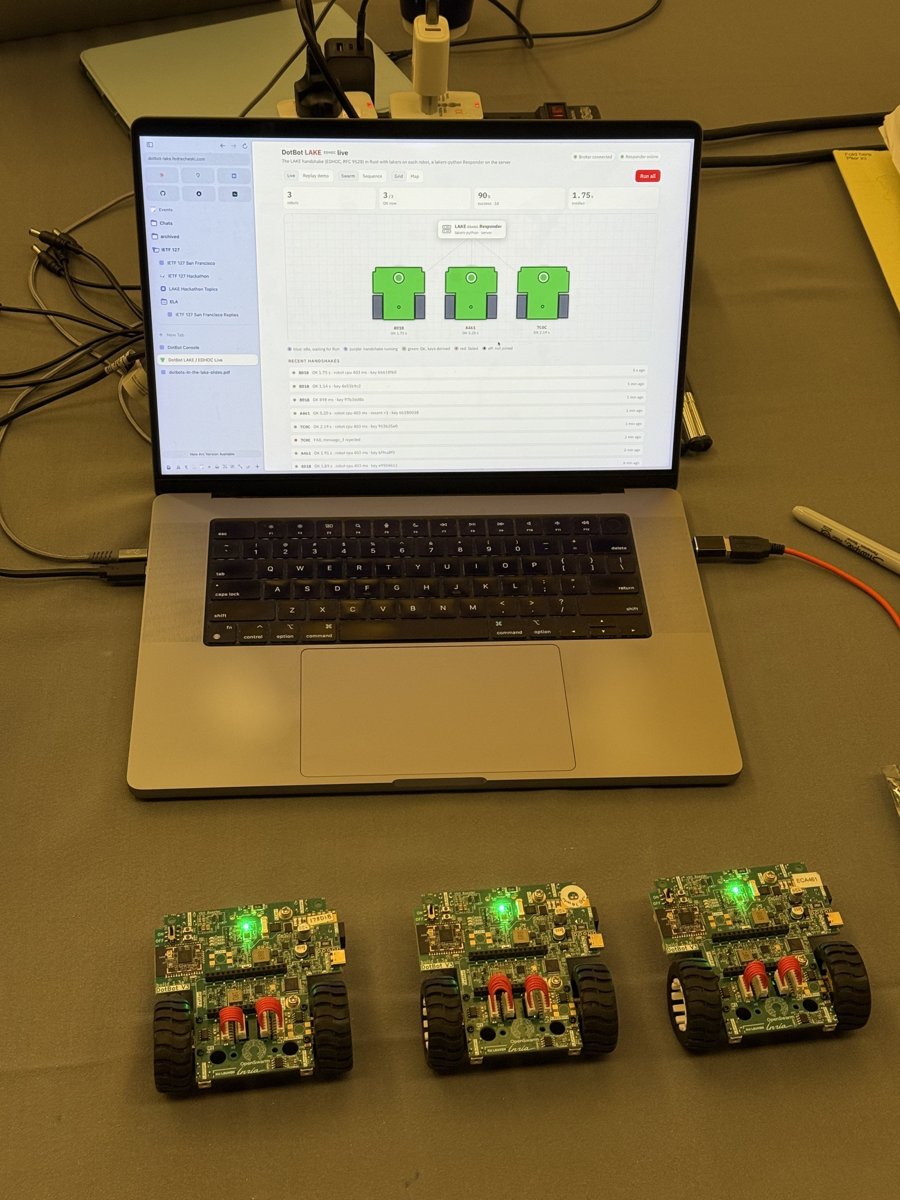
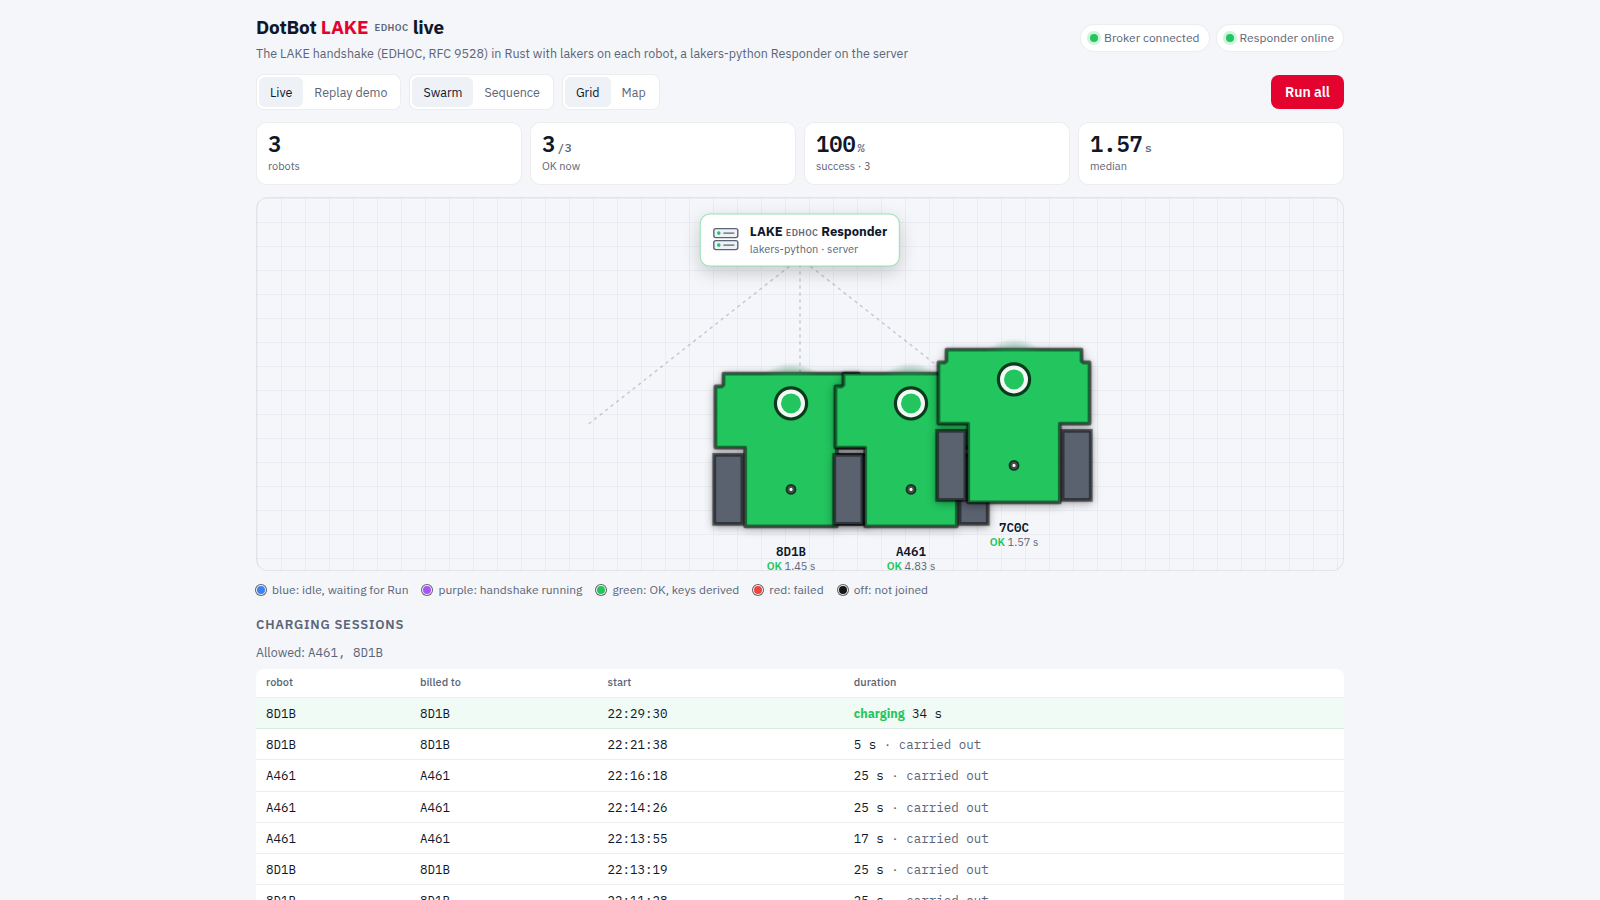
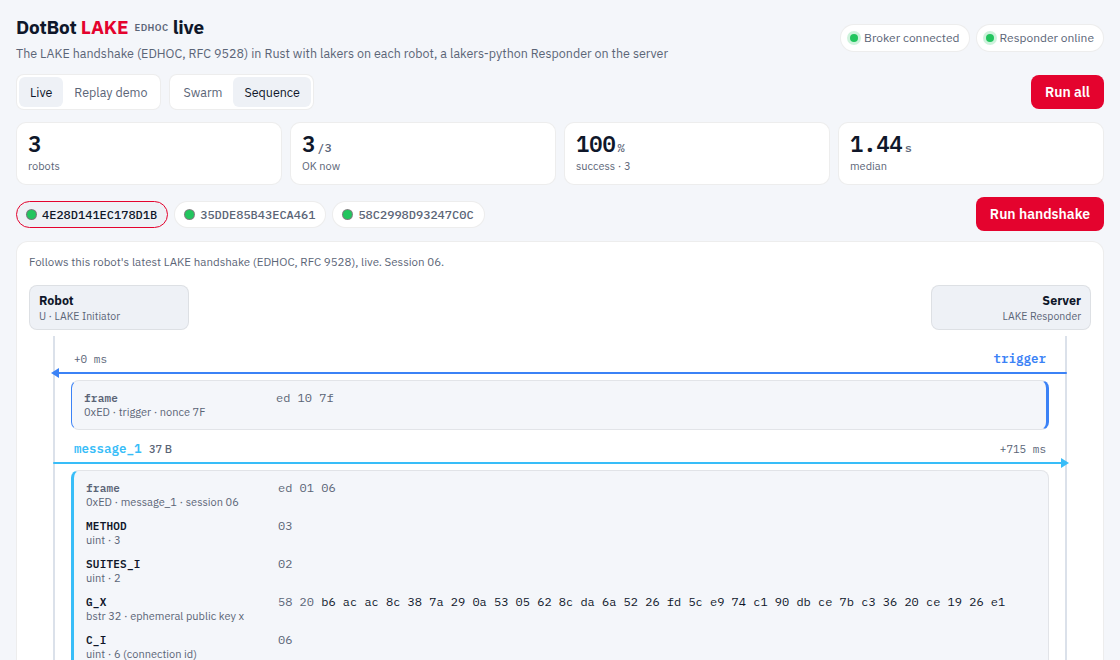
Swarm view with the 3 live robots, and a Sequence view with every byte on the air. ?demo=1 replays 5 simulated robots.
 try it livedotbot-lake.fedrecheski.com
 DotBotspydotbot.readthedocs.io
 lakersgithub.com/lake-rs/lakers